Skip to content
The Machine

The Machine · Elements

String robot

Prototype stage

Updated 2026-10-18

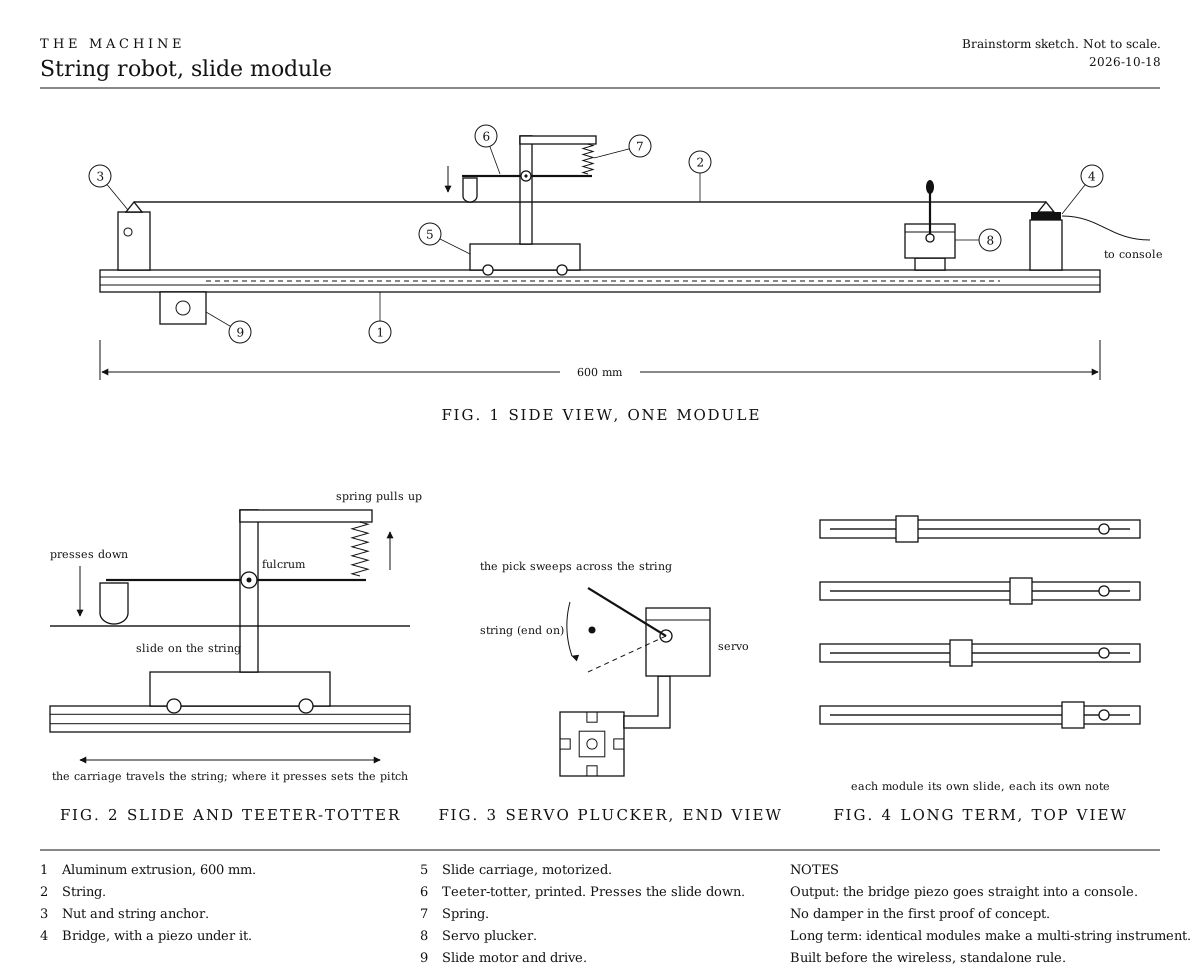
One string on 600 mm aluminum extrusion. Pitch comes from a motorized slide resting on the string, pressed by a spring-loaded teeter-totter.

One slide module. Side view, the slide and teeter-totter up close, the servo plucker end on, and modules side by side.
Fig. 1One slide module. Side view, the slide and teeter-totter up close, the servo plucker end on, and modules side by side.

How it works

  • One string on 600 mm aluminum extrusion.
  • Pitch: motorized slide resting on the string, pressed by a spring-loaded teeter-totter (printed parts).
  • Excitation: servo plucker.
  • Output: bridge piezo straight into a console.
  • Damper left out for the first proof of concept.
  • Long term: identical modules combined into a multi-string instrument.

Notes

This unit predates the requirement that every instrument be wireless and standalone, and will need to be brought into the system design.